

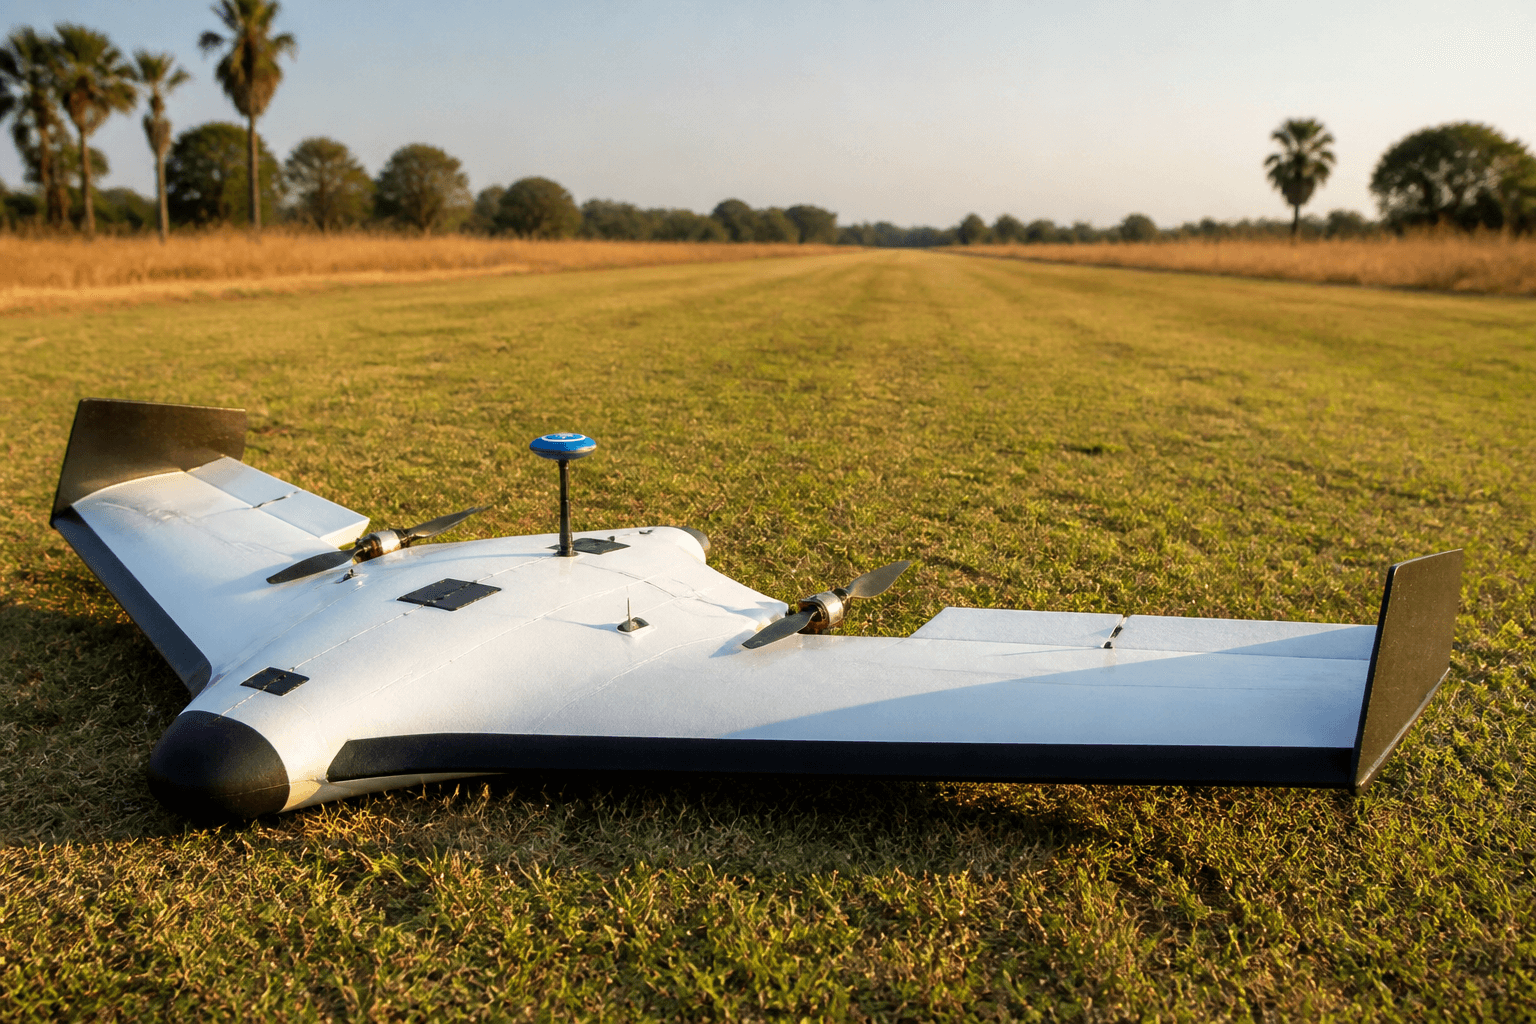
iNav for wings and cruisers

iNav (officially INAV) is firmware for pilots who care more about navigation, return to home and fixed-wing mixing than freestyle propwash. It shares roots with Betaflight (a similar configurator, CLI habits, much of the same hardware), but the goals differ. Betaflight is built for acro response on a multirotor. iNav is built around where the aircraft is and how it gets home. The wrong firmware costs you weekends; the right one makes long-range wings and GPS cruisers boring in the best way.
When NOT to switch to iNav
| Pilot / build | Stay on Betaflight |
|---|---|
| 5" freestyle acro | BF is the tool; iNav feels wrong in flips |
| Tiny whoop indoor | No GPS benefit; tuning ecosystem is BF |
| "I want GPS rescue on my flip quad" | BF has GPS Rescue, and 2025.12 added position and altitude hold; see failsafe scenarios |
| You hate relearning CLI | iNav is not a skin swap |
| Racing quads | BF latency and acro features win |
iNav on a hard-flown freestyle quad is like highway tyres on a dirt bike: it rolls, but nobody has fun.
Who should consider iNav
- Fixed-wing and VTOL cruisers that need stable self-levelling and nav modes
- Long-range quads with GPS missions, waypoints, and reliable RTH
- Mapping / exploration builds where position hold matters more than split-S tracking
- Pilots building a 7-inch explorer as a second rig, not a replacement for the acro quad
Stay on Betaflight for acro freestyle and tight whoop tuning unless you enjoy relearning mixer and mode logic from scratch.
| Aircraft | iNav | Betaflight |
|---|---|---|
| Fixed-wing / wing | ✅ | Poor mixer fit |
| 7" LR multirotor | ✅ RTH | BF if acro-only |
| 5" freestyle / whoop | ❌ | ✅ |
No GPS and no nav modes planned? You are probably on the wrong firmware.
What iNav is actually good at
| Capability | Why it matters |
|---|---|
| GPS position hold / RTH | A mature nav stack at the core of the firmware |
| Fixed-wing mixers | Aileron / elevator / throttle logic for wings |
| Waypoints & missions | Repeatable paths for cruisers |
| Geozone / failsafe logic | Safer long-range habits with planning |
| Cruise and angle modes | Relaxed flying when not acro |
Betaflight GPS Rescue can save a lost-link moment on a freestyle quad, and Betaflight 2025.12 added GPS position hold and altitude hold (release notes). It still has no waypoint missions or fixed-wing support, and navigation is not what it is tuned for.
Setup outline (high level)
Details vary by target, so read the iNav release notes for your FC. Outline:
1. Flash the iNav target for your exact FC (not a “close enough” one)
2. Wire GPS (UART), compass if required by config, RX per target docs
3. Calibrate the accelerometer level, on a stable surface
4. Configure mixer: multirotor vs fixed-wing vs hybrid
5. Set modes (angle, horizon, nav RTH, manual) and test the switches on the bench
6. GPS: wait for 3D fix outdoors, verify sat count in configurator
7. Test RTH and failsafe on OPEN ground, low altitude first
8. Log or DVR first nav flight, note overshoot and loiter behavior
See GPS module install for wiring and mount basics shared across firmwares.
Tuning in iNav uses different terms: position loops, navigation gains, fixed-wing PIFF profiles. Do not paste Betaflight PIDs into iNav and expect it to fly.
Fixed-wing vs multirotor in iNav
Wings benefit most: airspeed (or throttle as a stand-in), bank limits and return paths that assume forward flight. Sort out stall behaviour and level modes before you climb.
Multirotor cruisers use iNav for loiter, RTH and missions. Tune hover stability in angle mode before enabling autonomous legs. Heavy rigs need patience with I and navigation gains: the same discipline as BF, different names.
vs Betaflight GPS rescue
| Aspect | Betaflight rescue | iNav RTH |
|---|---|---|
| Primary use | Acro quad emergency | Nav-first aircraft |
| Position hold | Added in 2025.12 | Core feature |
| Waypoints | No | Yes |
| Wing support | Wrong tool | Native mixers |
| Pilot expectation | "Save my flip quad" | "Fly home and loiter" |
BF rescue works for experienced pilots who understand its limits. iNav treats position as the core job, which suits 7-inch exploring and fixed-wing cruising.
Failsafe and legal context
Configure failsafe before range tests: drop, land or RTH. Walk through failsafe scenarios on paper, then in a field with a spotter.
India: GPS lock between tall buildings is slow, so test sky view at your actual field, not from a balcony. Buildings and metal roofs block satellites. The DGCA rules still apply to where and how you fly; nav firmware does not grant airspace rights.
Common mistakes
- Flashing iNav without GPS wired: nav modes are unavailable or behave badly
- First RTH test over trees or water; test over open grass
- Ignoring compass calibration on targets that need it
- Using BF acro rates mindset on a wing in angle mode
- Expecting iNav to fix a poorly built wing; CG and control throws still matter
When to run both firmwares
Many pilots run Betaflight on the freestyle quad and iNav on the wing or LR cruiser: same radio, different models. That beats flashing one FC back and forth every week.
Tuning workflow (iNav, practical)
- Bench: motors spin correct direction; modes switch correctly
- Hover or hand-launch: trim surfaces / PID in manual or angle
- GPS: 3D fix confirmed; home set with clear sky
- RTH test: low altitude, ample space, kill switch ready
- Iterate nav gains only after manual flight is boring
iNav has Blackbox too; use it when a wing oscillates in wind or a quad hunts in loiter. Same philosophy as reading Blackbox: one change, one flight.
India field notes
Summer thermals and dust storms affect wings far more than indoor whoops. Midday heat also stresses ESCs on heavy LR quads; see filter tuning for hot climates.
Monsoon cloud and rain hurt visibility and GPS; fly nav missions in clear weather, and follow monsoon storage habits between seasons.
First RTH test: good satellite fix, home set while stationary, trigger RTH low over open grass, kill switch ready. Never first-test over water or from a terrace; in a city, a GPS fix can take minutes. Wings need the right CG and airspeed settings before nav modes; navigation cannot fix a tail-heavy plank.
iNav is not "better Betaflight." It is the right tool when the mission is come home safely and cruise efficiently. Keep acro on BF; let iNav do what it was built for.
Discussion
Comments aren't open on this post yet. Share it with your build group, or start a thread on X.